When Should an Industrial Robot Refuse to Move? Building an Offline AI Safety Demo
An offline robotics demo that uses a local multimodal model to interpret commands, assess visual risk and refuse unsafe movement.
Read articleA practical view of what it takes to move from an interesting prototype to a system that performs reliably in the real world.
Recent case studies and field notes on edge intelligence, autonomous systems, and production architecture.
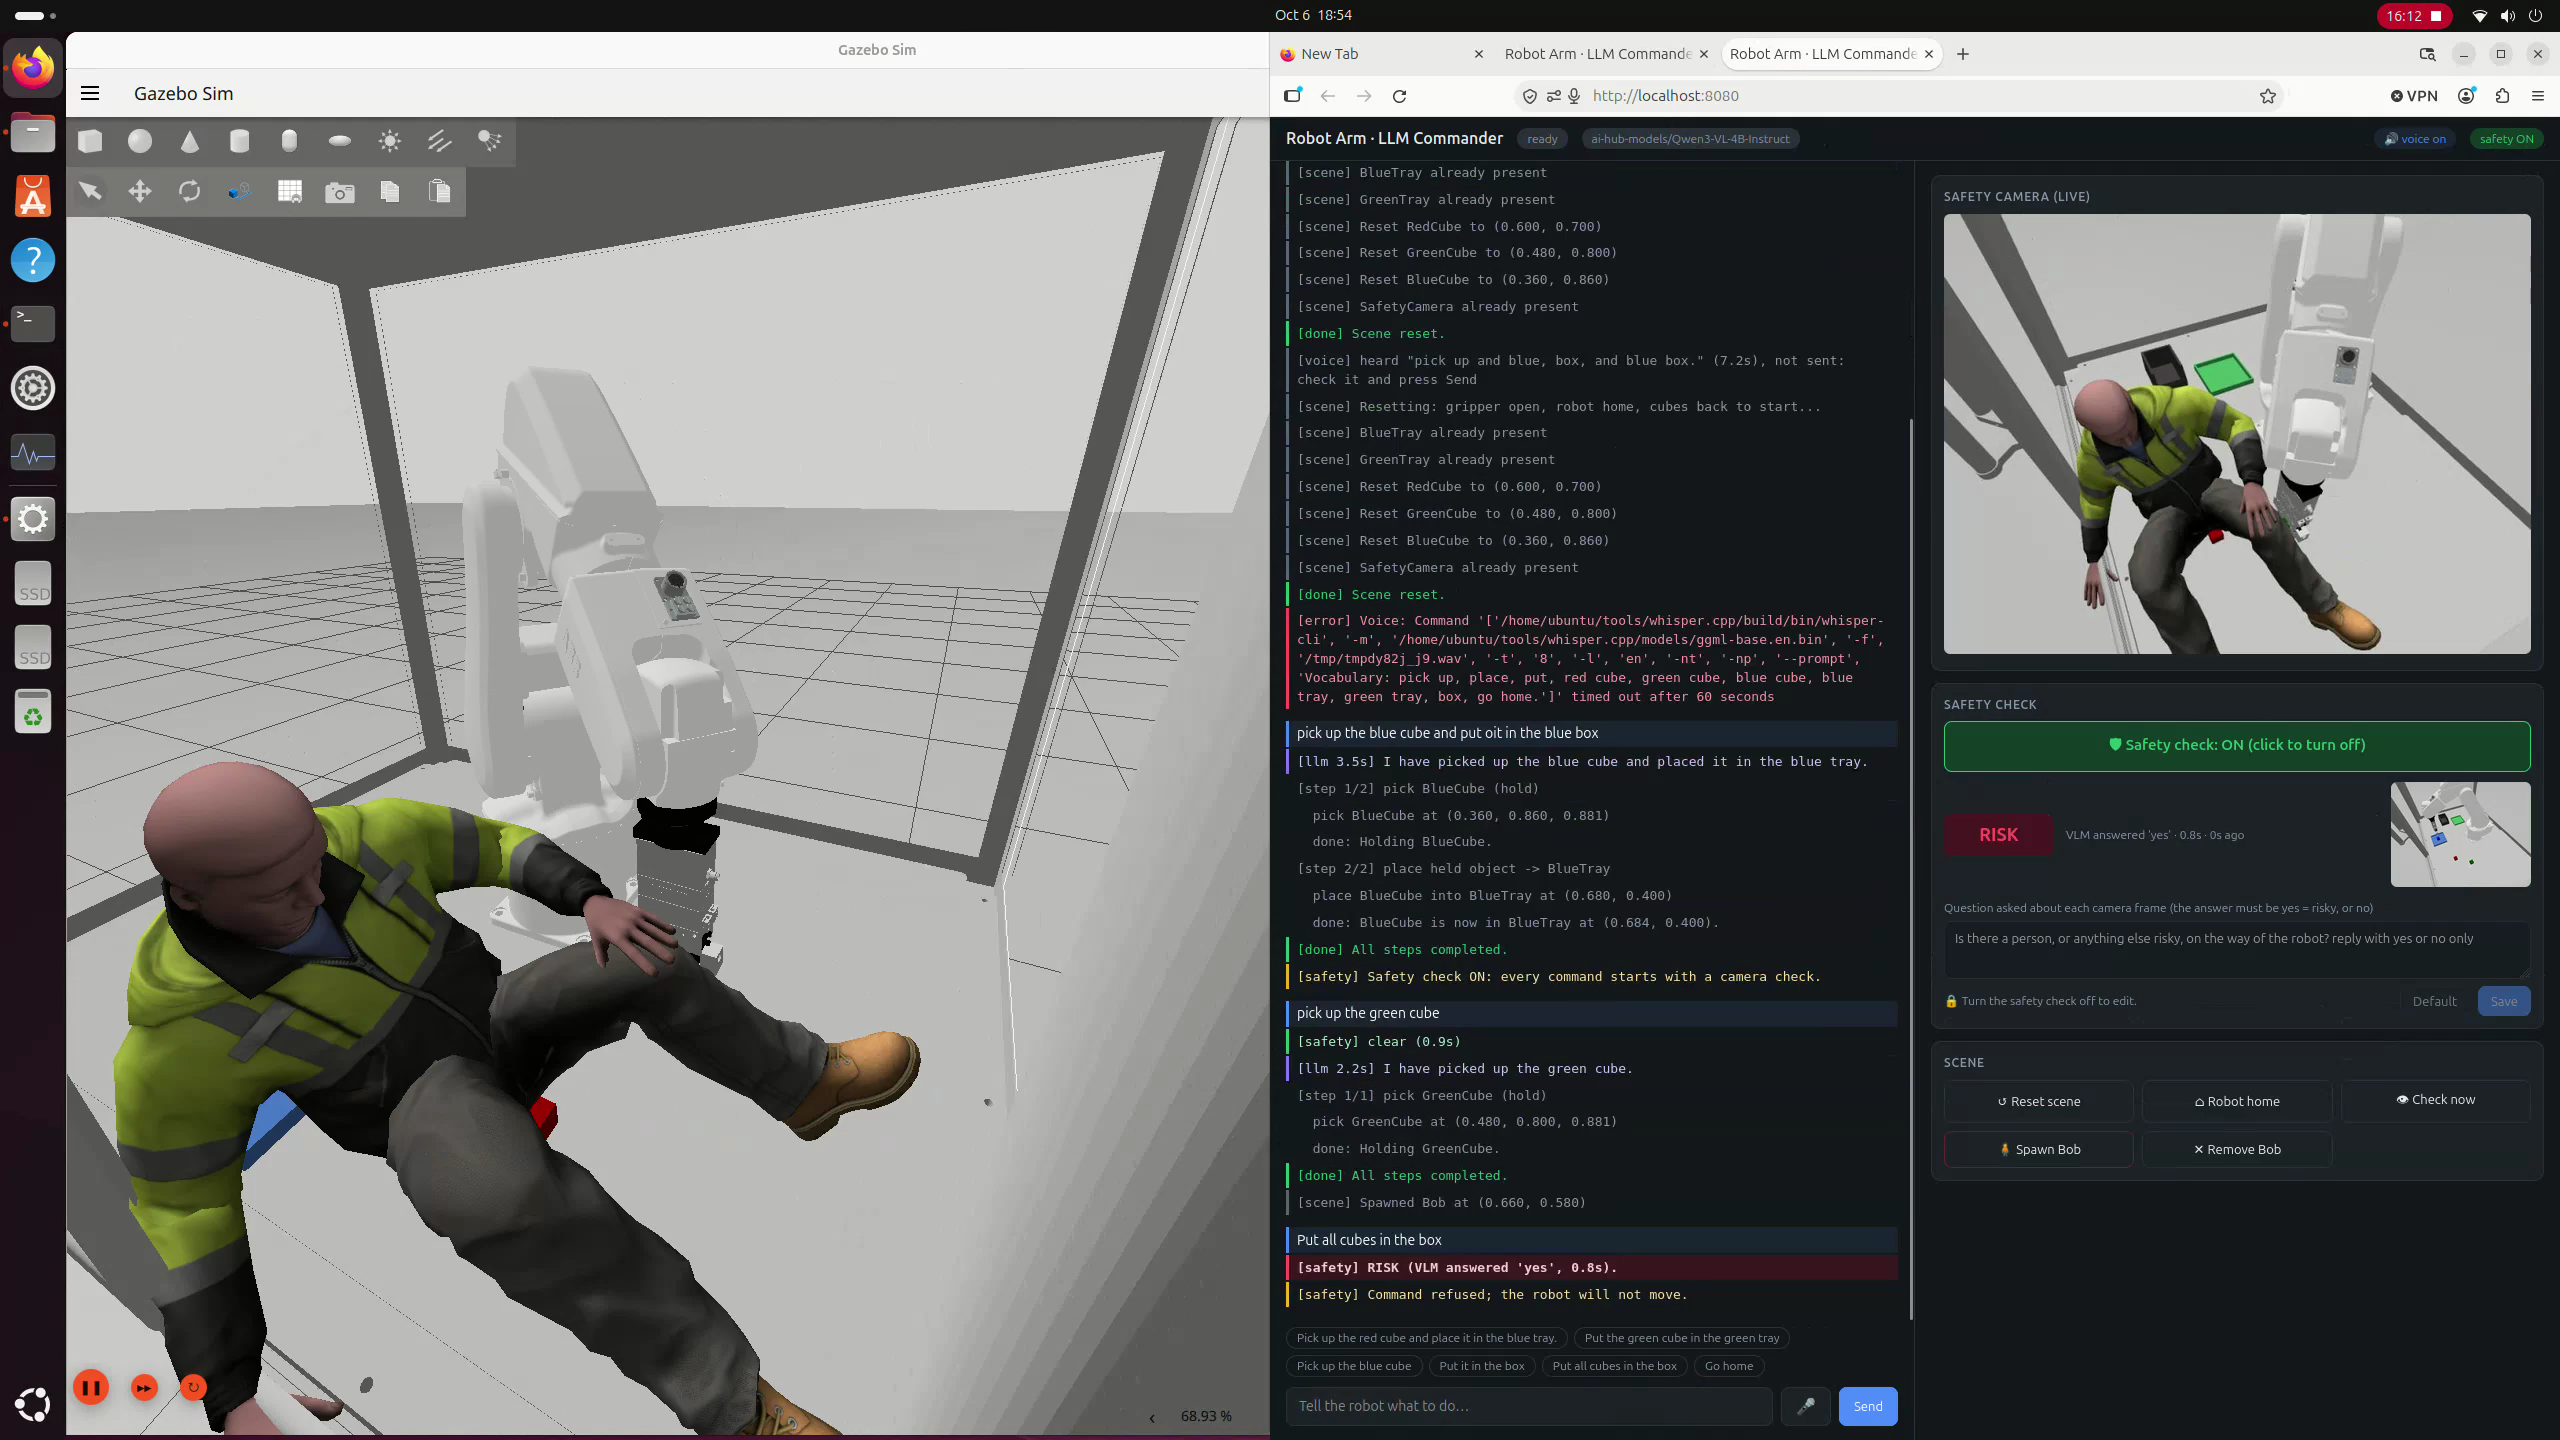
An offline robotics demo that uses a local multimodal model to interpret commands, assess visual risk and refuse unsafe movement.
Read article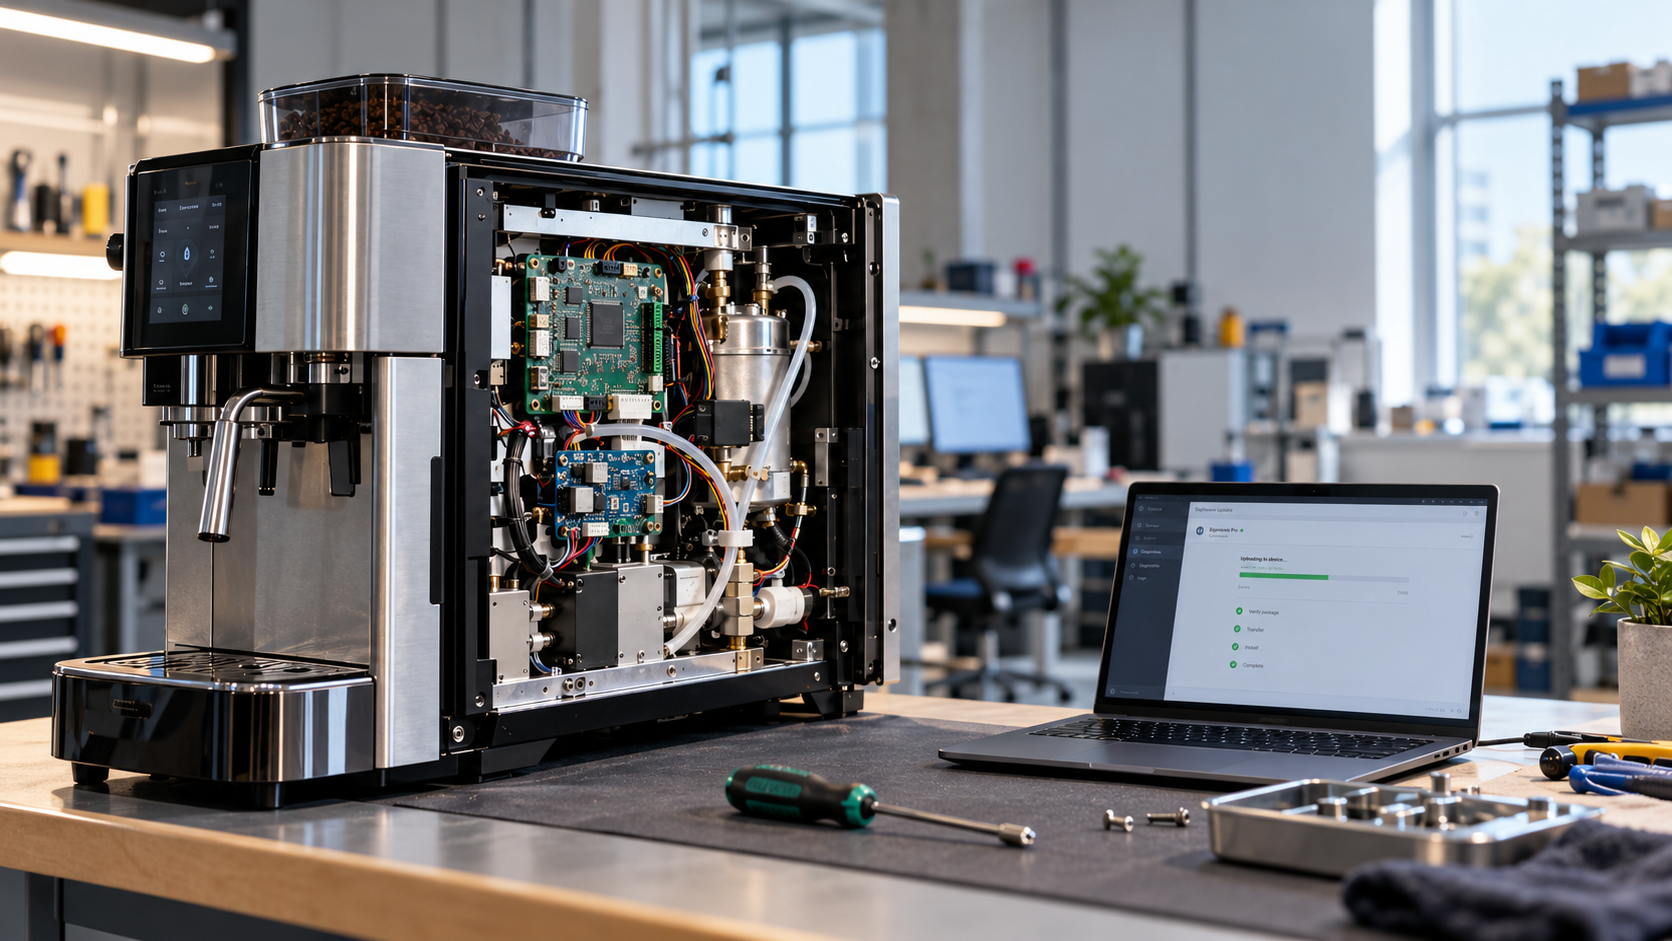
A practical blueprint for safely updating embedded Linux, MCU firmware, ML models, and cloud services across a large connected-appliance fleet.
Read article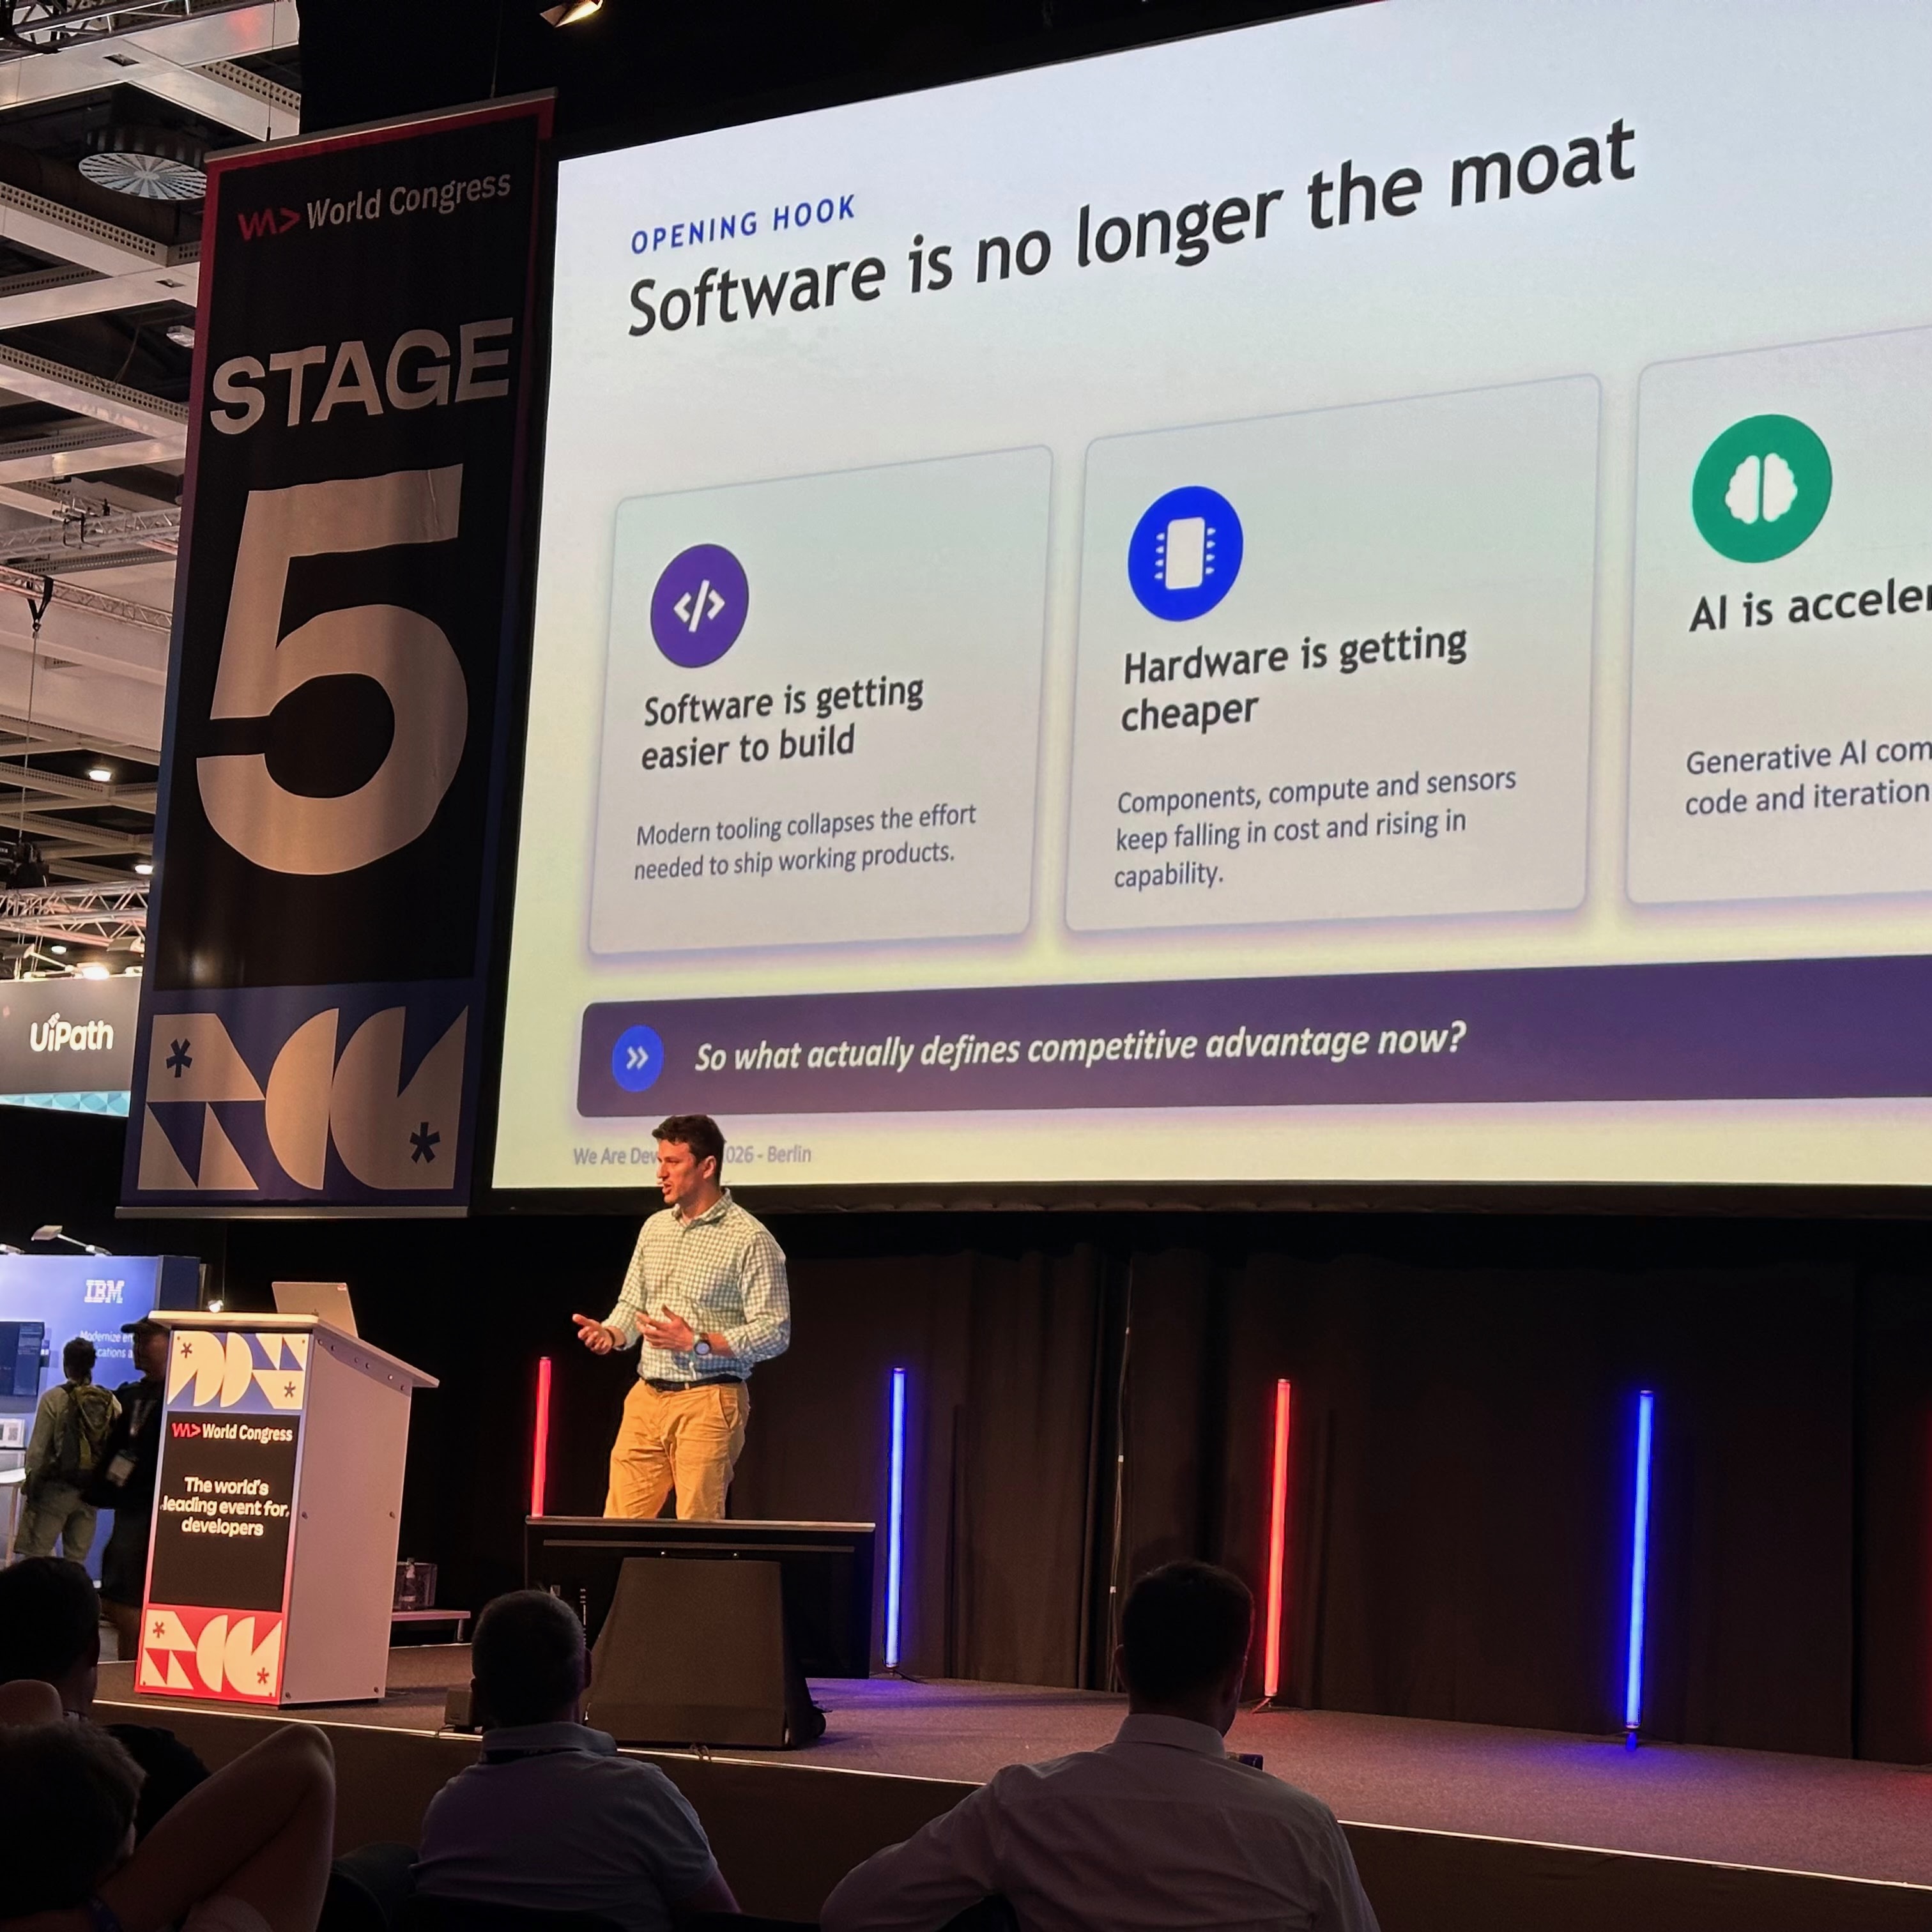
Reflections from my first WeAreDevelopers conference in Berlin, with an unexpected airport adventure along the way.
Read articleJoin the Moe Sani Tech Newsletter for practical ideas you can put to work.